AETHER / DODEXADrawing archive 01—06

THE SYSTEM
ON PAPER.

Six concept sheets map the path from a single active cell to a buildable hybrid robot and a consent-governed global field network.

Concept blueprint overview of the DODEXA field robot

Drawing statusFunctional concept / dimensions intentionally open

00 / Reading the drawings

Architecture first.
Numbers after evidence.

The sheets define responsibilities, interfaces, and service boundaries. They intentionally omit dimensions and operating values that could only be justified by coupon testing.

BP—01

Unit cell architecture

Open full resolution
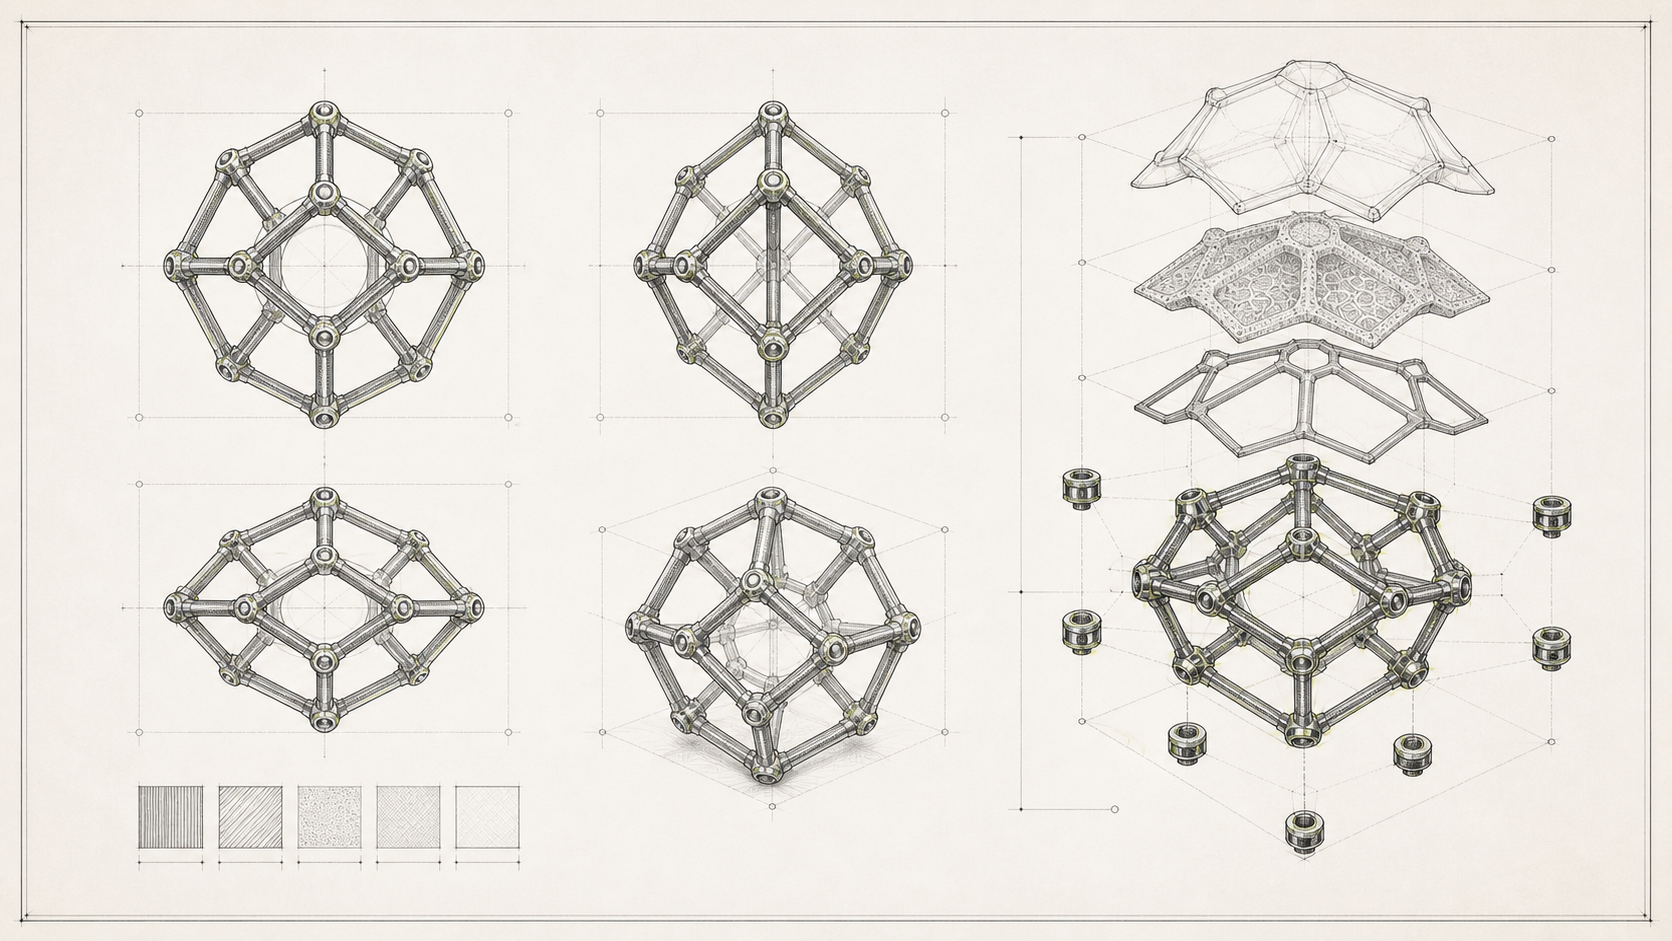
Orthographic and exploded concept blueprint of a rhombic-dodecahedral DODEXA unit cell

The cell is a repeatable chassis. Its geometry carries load and separates structural, field, active, and guest-response functions for inspection.

  1. A
    Structural latticePrimary passive load path
  2. B
    Field junctionRegistration and remote bias
  3. C
    Active skinCandidate electro-ionic trim layer
  4. D
    Guest volumeOptional environmental response
BP—02

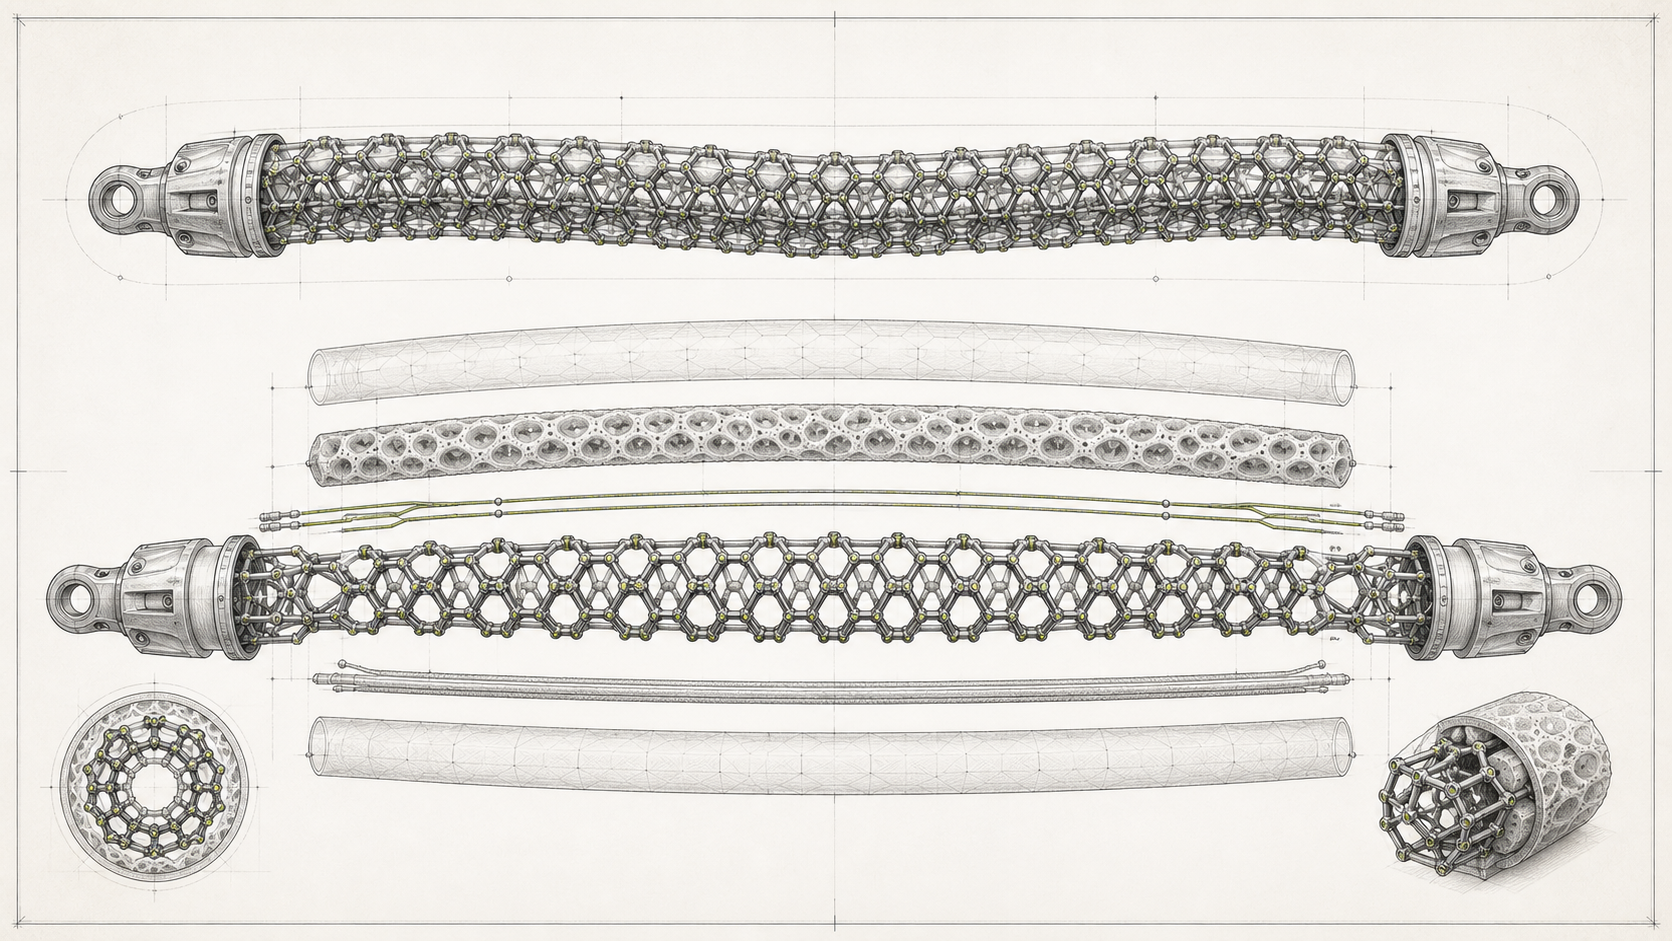
Tendon stack

Open full resolution
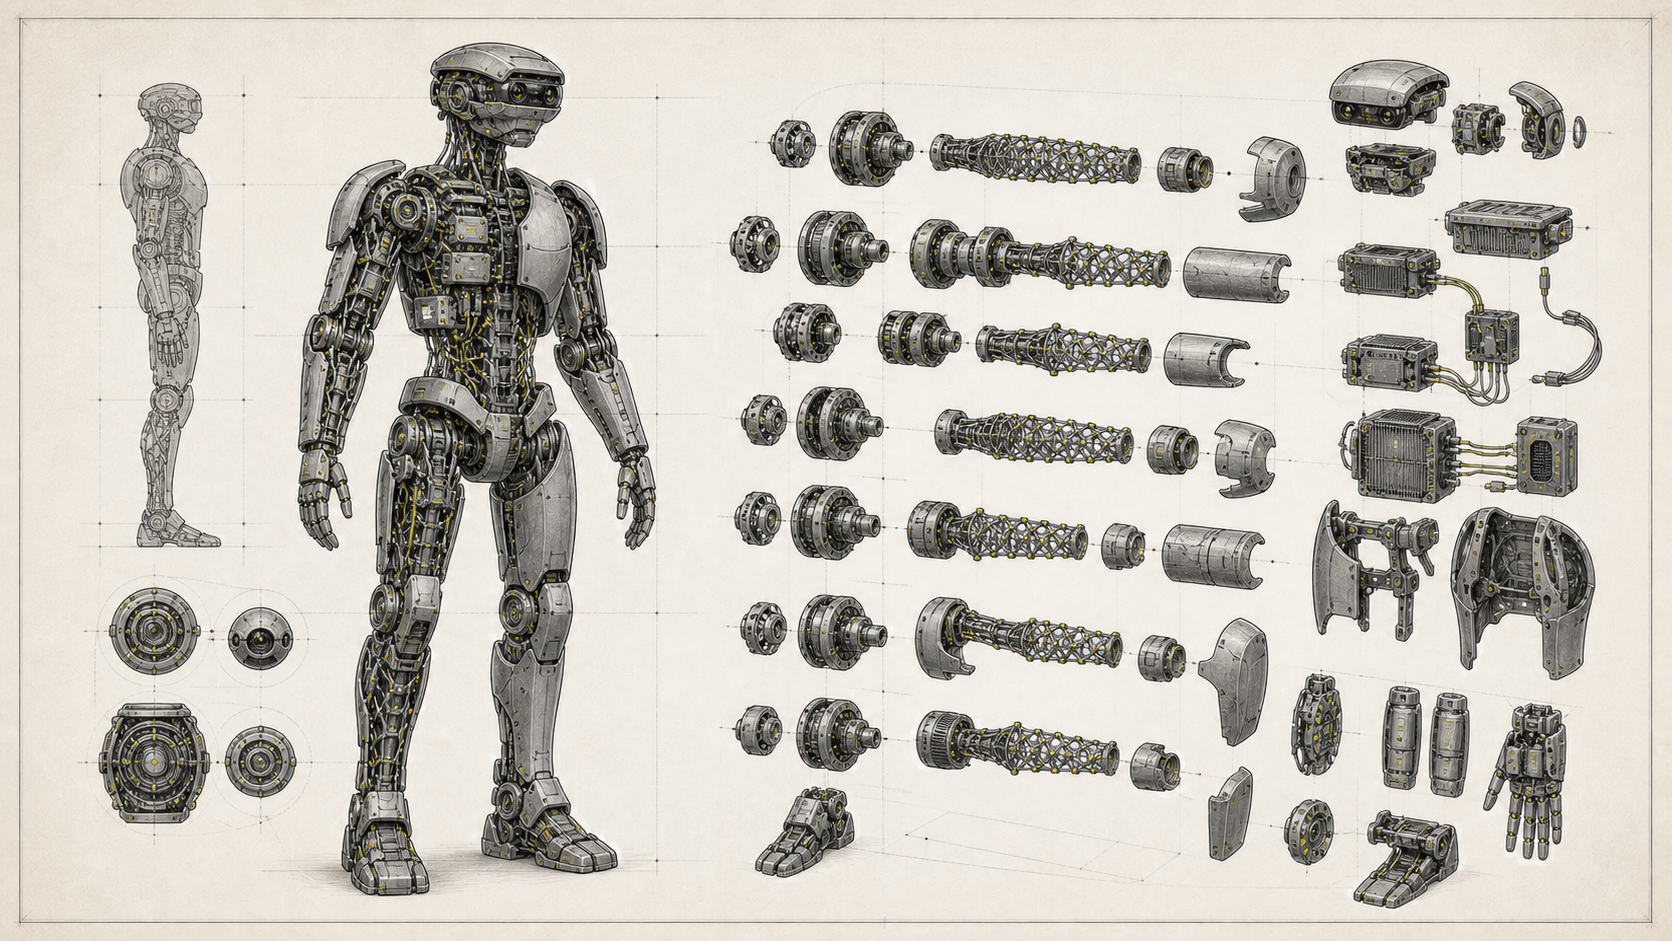
Longitudinal exploded concept blueprint of a DODEXA artificial-muscle tendon

Cells become a tendon only when their interfaces share load, route signal, reject heat, and remain serviceable as a cartridge.

  1. A
    Cell trainRepeated mechanical core
  2. B
    Node chainField-addressed registration
  3. C
    Local busSensing and active-layer access
  4. D
    Compliant barrierIsolation without locking motion

BP—03

Robot integration

Open full resolution
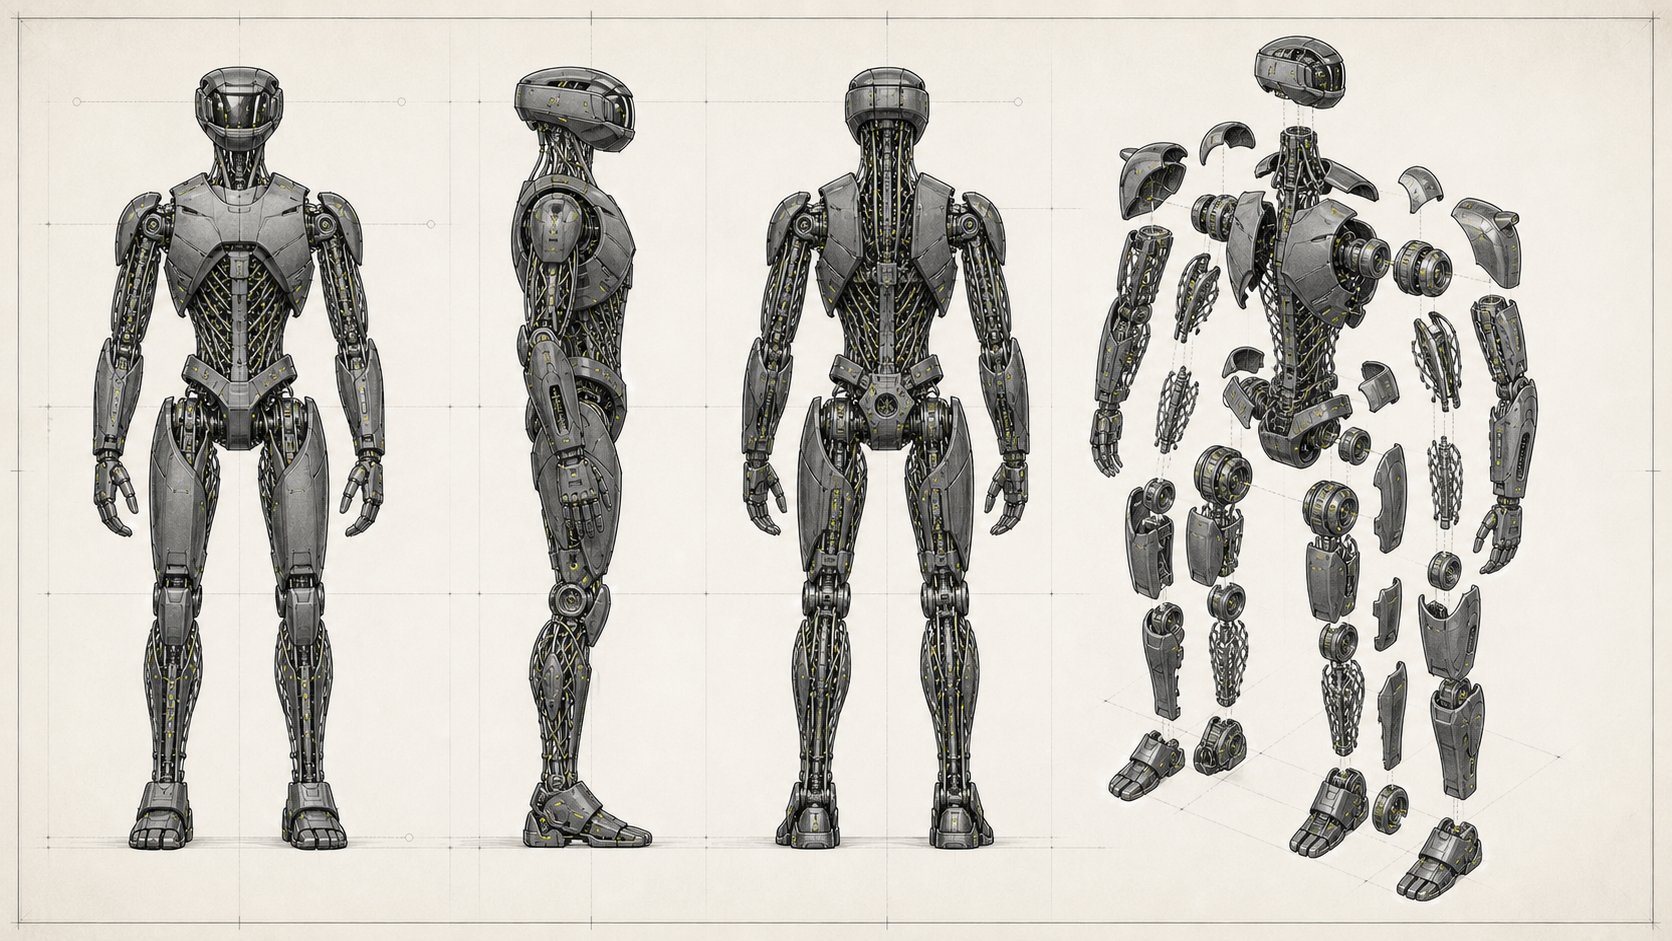
Front, side, rear, and exploded concept blueprint of a bipedal DODEXA field robot

The robot is organized around visible, replaceable tendon routes. Joint cartridges remain accessible; armor does not hide the evidence path.

  1. A
    Tendon routesPaired agonist and antagonist bundles
  2. B
    Joint cartridgesMechanical stops, sensing, and service
  3. C
    Control coreLocal power, state estimation, and safety
  4. D
    Passive frameLoad path after active-channel loss

04—06 / Practical architecture

Build the machine now.
Keep the muscle experimental.

A new source-backed blueprint separates what qualified factories can make today from the active-matter research that still belongs on an instrumented rig.

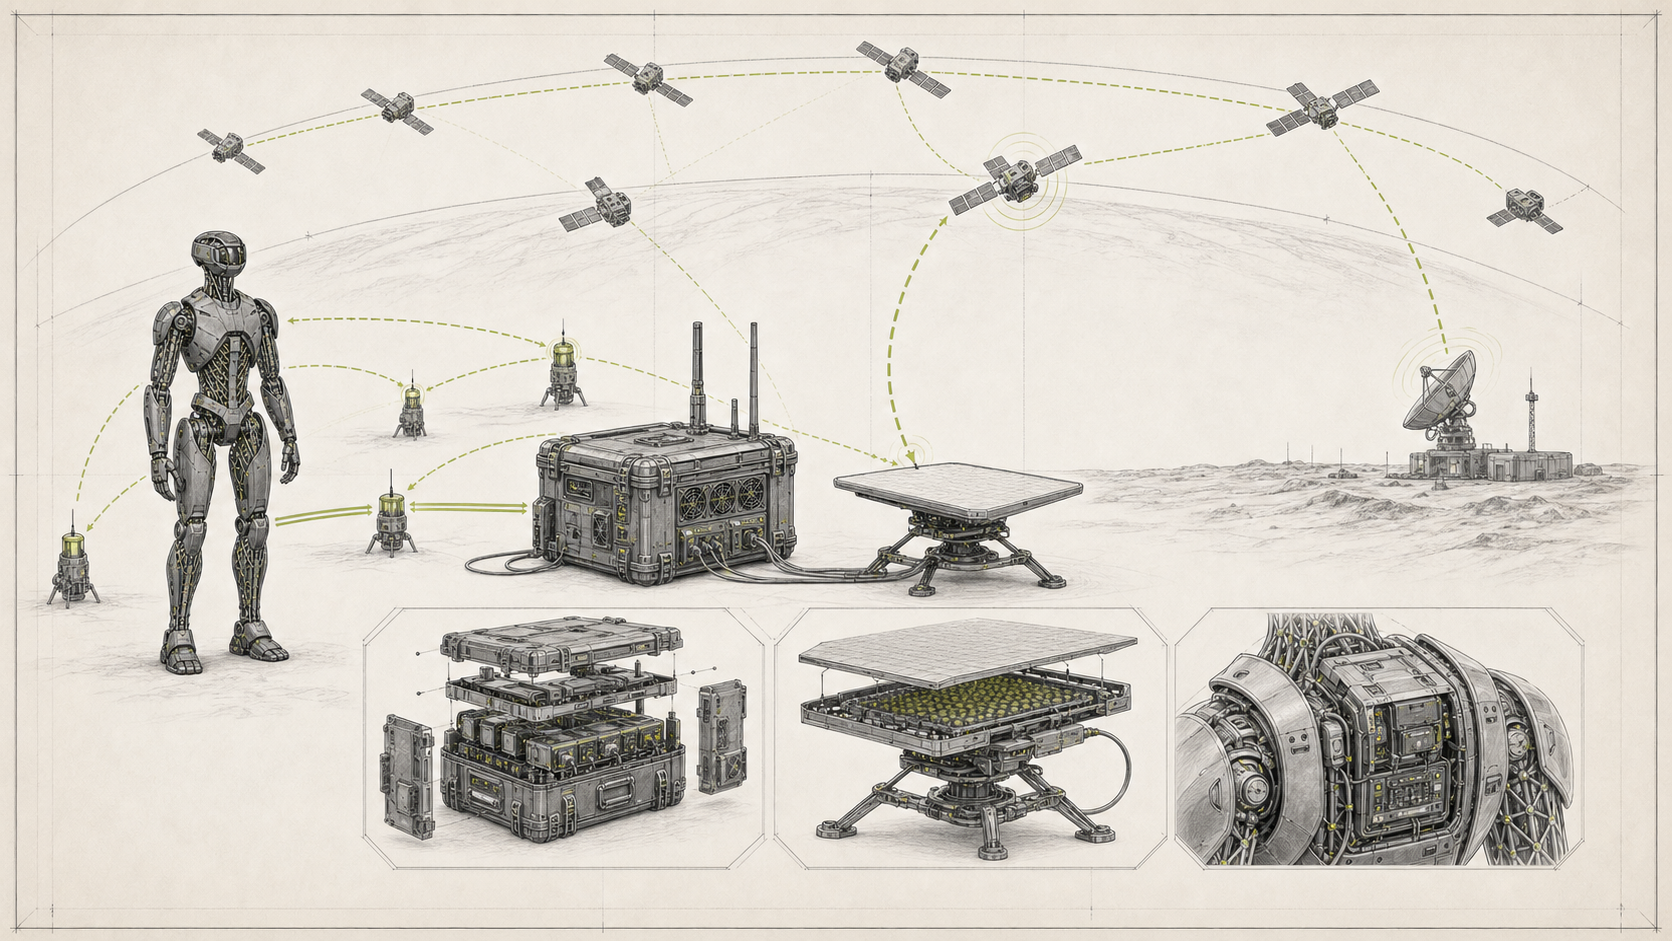
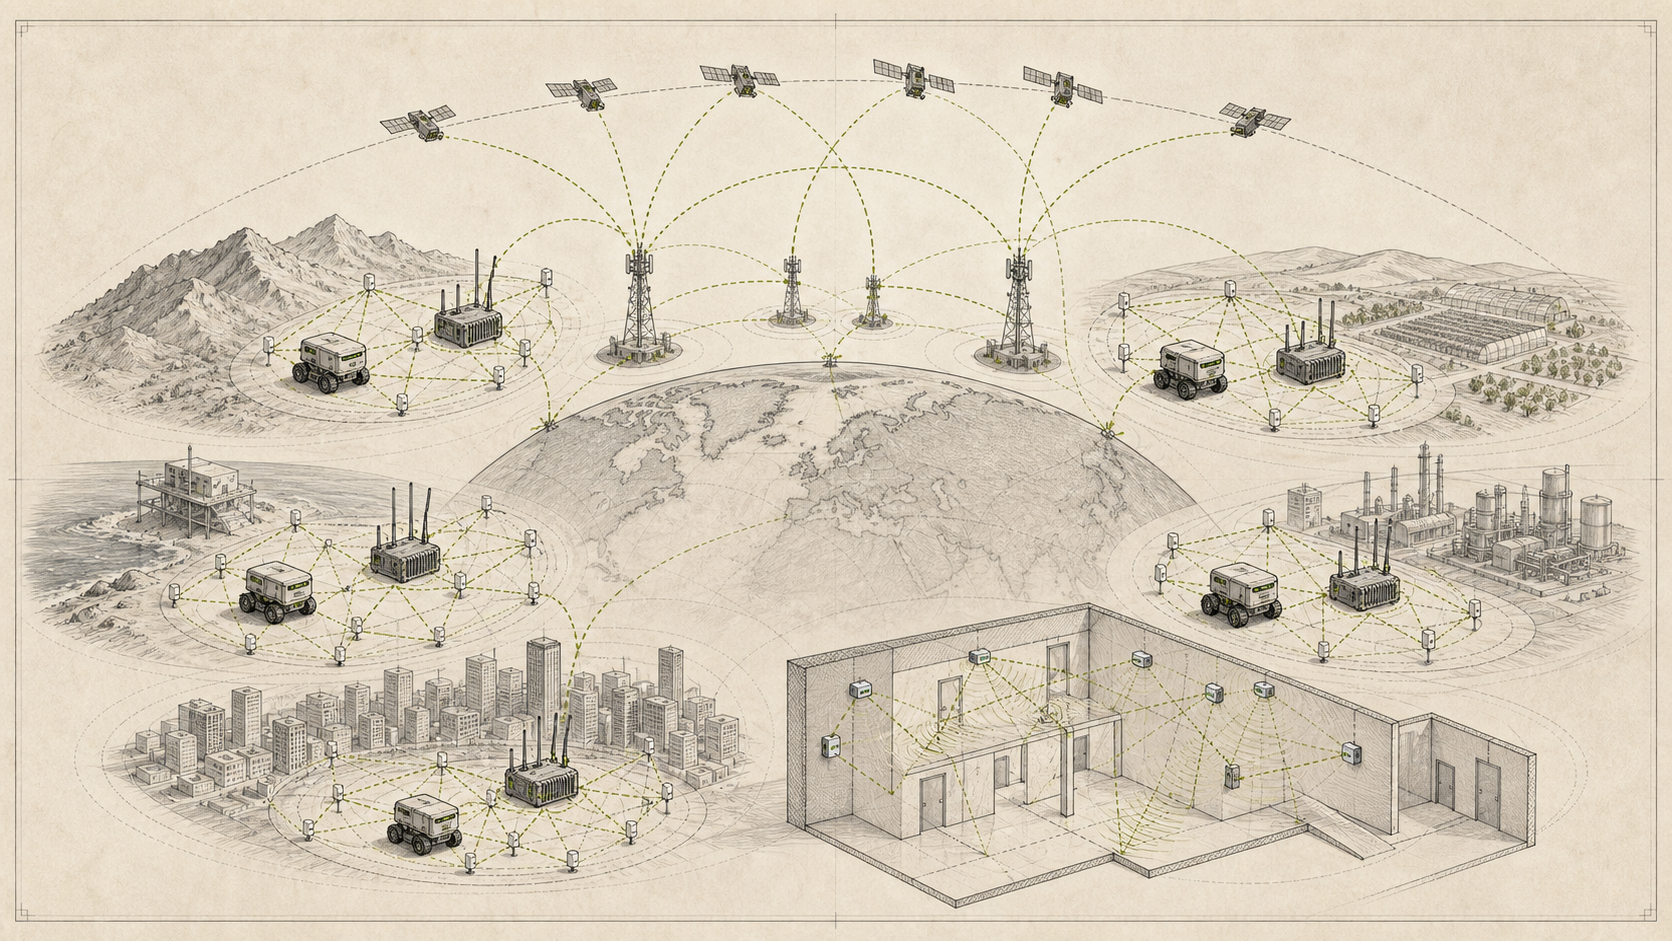
Practical 2026 hybrid DODEXA robot system blueprintBP—04 / Hybrid robotA practical 2026 build stack.Materials, joint cartridges, factories, test order, and the better modular architecture.Open Build Today BP—05 / Satellite networkStarlink as horizon—not nervous system.DODEXA satellite and local field-network blueprintBP—06 / Global federationOne identity plane. Many local cells.Global DODEXA network blueprint connecting regional Wi-Fi cells, low-rate gateways, and satellite backhaul

07 / Blueprint maturity

What these sheets are.
And what they are not.

Blueprint is used here as a systems-design artifact. Fabrication requires qualified drawings, measured tolerances, risk controls, and domain review.

LayerMaturityBoundary
Functional intentDefinedLayer responsibilities and validation questions are explicit.
System architectureConcept levelInterfaces and load paths are proposed, not integrated hardware.
Dimensions + tolerancesOpenThey must follow material characterization and manufacturing trials.
Materials + processesCandidate spaceNo alloy, coating, polymer, electrolyte, or cure schedule is qualified.
Fabrication readinessNot readyThese drawings must not be used as shop instructions or safety specifications.
CertificationNoneNo performance, field exposure, lifecycle, or human-safe envelope is certified.

Continue / Research journal

Read the reasoning
behind every line.

Open the journal